
Functions
Ref. Model
I/O Data
SubAIMs
JSON MData
Profiles
Ref. Software
Conformance
Performance
1 Functions
The Trajectory Planning and Decision (CAV-TPD) AIM:
| Receives | Basic Offline Map Object | The Offline Map. |
| Full Environment Descriptors | From Full Environment Description. | |
| AMS Data | From AMS Memory. | |
| Alert | From the Environment Sensing Subsystem. | |
| AMS-MAS Message Response | From the Motion Actuation Subsystem. | |
| Route Response | From Route Selection Planning. | |
| Produces | Route Request | To Route Selection Planning. |
| Full Environment Descriptors | To AMS Memory. | |
| AMS-MAS Message Request | To the Motion Actuation Subsystem. | |
| Path | To AMS Memory. | |
| CAV State | To Full Environment Description. | |
| Road State | To Full Environment Description. | |
| AMS Data | To AMS Memory. |
From the Route to be driven, the AIM decides how the CAV moves: the Path along the lanes of the Route, the Trajectory of the next seconds along the Path, and that Trajectory refined against obstacles and the state of the road – the AMS-MAS Message the Motion Actuation Subsystem executes.
2 Reference Model
Figure 1 depicts the Reference Model of the Trajectory Planning and Decision (CAV-TPD) AIM.
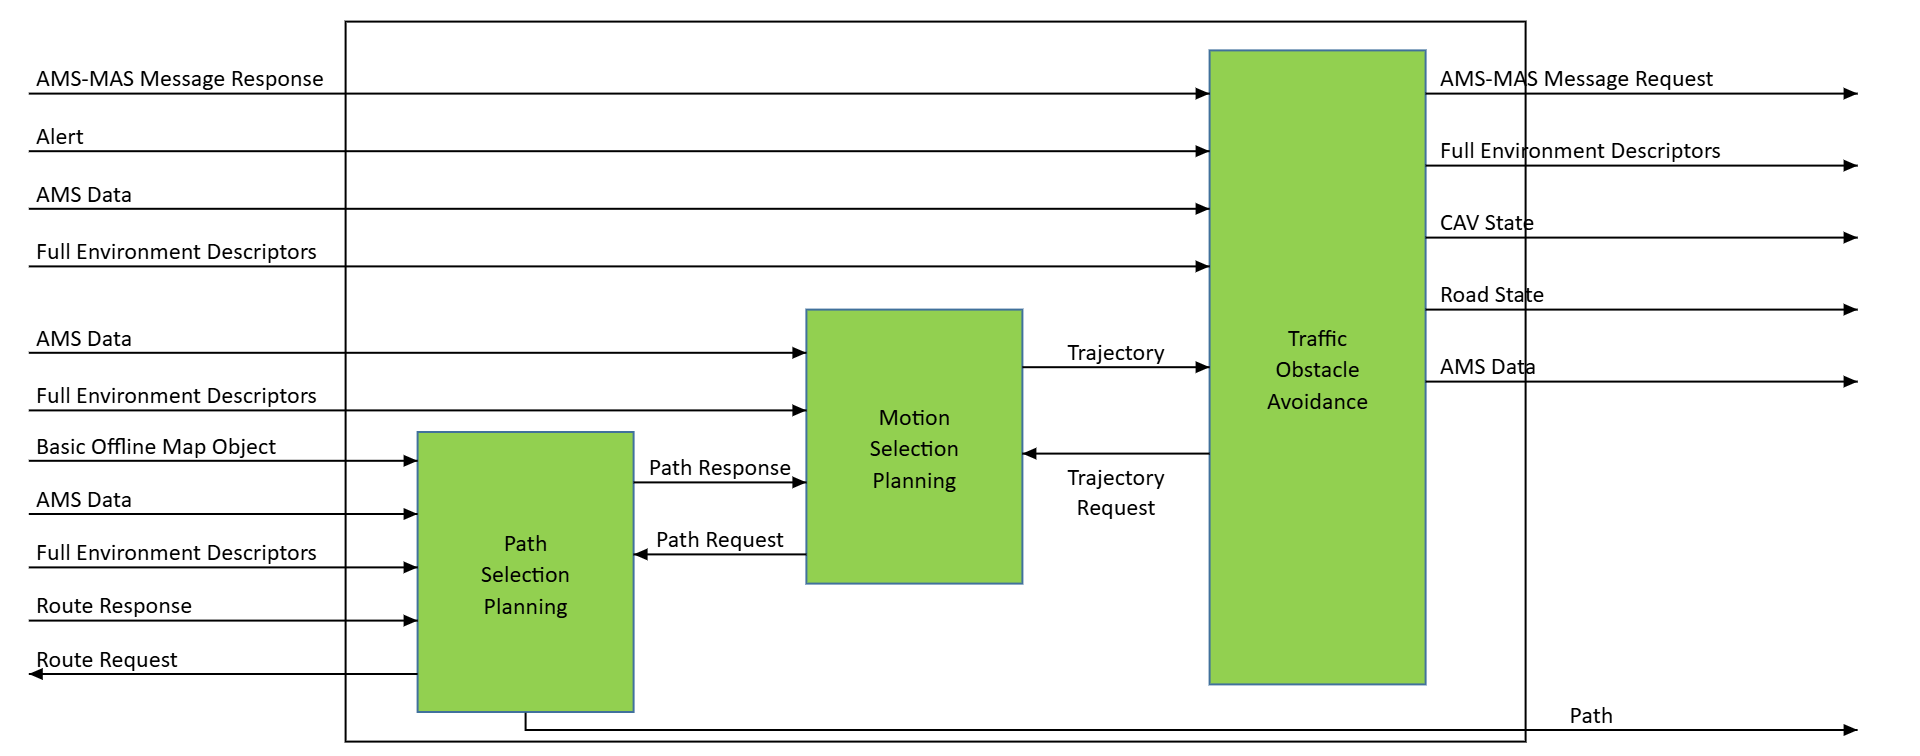
Figure 1 – The Trajectory Planning and Decision (CAV-TPD) AIM
3 I/O Data
Table 1 specifies the Input and Output Data of the Trajectory Planning and Decision (CAV-TPD) AIM.
| Input | Data Type | Description |
|---|---|---|
| Basic Offline Map Object | Basic Offline Map Object | The lanes and junctions the Path follows. |
| Full Environment Descriptors | Full Environment Descriptors | The CAV and the objects around it on the map. |
| AMS Data (optional) | AMS Data | What the AMS has decided before. |
| Alert (optional) | Alert | Something that calls for an immediate reaction. |
| AMS-MAS Message Response (optional) | AMS-MAS Message Response | The MAS’s answer: its Spatial Attitude and the Road State. |
| Route Response | Interaction Response | The Route to be driven. |
| Output | Data Type | Description |
| Route Request (optional) | Interaction Request | A segment of the Route that cannot be driven. |
| Full Environment Descriptors (optional) | Full Environment Descriptors | The descriptors the decision was taken on. |
| AMS-MAS Message Request | AMS-MAS Message Request | The Trajectory to execute, with the Command. |
| Path (optional) | Path | The Path selected. |
| CAV State (optional) | CAV State | The state of the CAV. |
| Road State (optional) | Road State | The state of the road. |
| AMS Data (optional) | AMS Data | The record of the decisions. |
4 SubAIMs
4.1 Functions of SubAIMs
Table 2 specifies the Functions of the SubAIMs of the Trajectory Planning and Decision (CAV-TPD) AIM.
| SubAIM | Function |
|---|---|
| Path Selection Planning | From the Route, the Path: the centreline of the CAV’s lane along each segment and through each junction. |
| Motion Selection Planning | From the Path, the Trajectory of the next seconds, following the object ahead and slowing at corners. |
| Traffic Obstacle Avoidance | The Trajectory refined against Alerts, the object ahead and the Road State; the AMS-MAS Message. |
4.2 Operation
Route Selection Planning gives the Route to be driven as a Route Response. Path Selection Planning gives the Path to Motion Selection Planning as a Path Response; a Route that cannot be driven is sent back as a Route Request.
For each Full Environment Descriptors instance, Motion Selection Planning gives the Trajectory of the next seconds along the Path to Traffic Obstacle Avoidance, which refines it and issues the AMS-MAS Message Request to the Motion Actuation Subsystem. The MAS’s AMS-MAS Message Response – its Spatial Attitude and the Road State – bounds the next refinements.
Every decision is given to AMS Memory with the Full Environment Descriptors it was taken on.
4.3 I/O Data of SubAIMs
Table 3 specifies the Input and Output Data of the SubAIMs.
| SubAIM | Input | Output |
|---|---|---|
| Path Selection Planning | Basic Offline Map Object – Basic Offline Map Object Full Environment Descriptors – Full Environment Descriptors AMS Data – AMS Data Route Response – Interaction Path Request – Interaction |
Route Request – Interaction Path Response – Interaction Path – Path |
| Motion Selection Planning | Full Environment Descriptors – Full Environment Descriptors AMS Data – AMS Data Path Response – Interaction Trajectory Request – Interaction |
Path Request – Interaction Trajectory Response – Interaction Trajectory – Trajectory |
| Traffic Obstacle Avoidance | Full Environment Descriptors – Full Environment Descriptors Trajectory – Trajectory AMS Data – AMS Data Alert – Alert AMS-MAS Message Response – AMS-MAS Message |
Full Environment Descriptors – Full Environment Descriptors AMS-MAS Message Request – AMS-MAS Message AMS Data – AMS Data Road State – Road State CAV State – CAV State Alert – Alert Trajectory Request – Interaction |
4.4 AIMs and JSON Metadata
Table 4 gives the AIMs and their JSON Metadata.
5 JSON Metadata
https://schemas.mpai.community/CAV2/V2.0/AIMs/TrajectoryPlanningAndDecision.json
6 Profiles
No Profiles.
7 Reference Software
The reference software runs Path Selection Planning, Motion Selection Planning and Traffic Obstacle Avoidance as one composite, continuously. It is part of the reference software of CAV-TEC V2.0 (see N4195, An introduction to the reference software): C# on .NET 10, released under the BSD 3-Clause licence, obtained from MPAI.
Tested with the Autonomous Motion Subsystem, Stage 1, end to end.
8 Conformance Testing
Table 5 provides the Conformance Testing Method for the Trajectory Planning and Decision (CAV-TPD) AIM: the data it receives and produces. If a schema references other schemas, conformance of data for the primary schema implies that data referencing a secondary schema shall also validate against that schema, if present, and conform with the Qualifier, if present.
| Receives | Basic Offline Map Object | Shall validate against the Basic Offline Map Object schema. |
| Full Environment Descriptors | Shall validate against the Full Environment Descriptors schema. | |
| AMS Data | Shall validate against the AMS Data schema. | |
| Alert | Shall validate against the Alert schema. | |
| AMS-MAS Message Response | Shall validate against the AMS-MAS Message schema. | |
| Interaction Response | Shall validate against the Interaction schema. | |
| Produces | Interaction Request | Shall validate against the Interaction schema. |
| Full Environment Descriptors | Shall validate against the Full Environment Descriptors schema. | |
| AMS-MAS Message Request | Shall validate against the AMS-MAS Message schema. | |
| Path | Shall validate against the Path schema. | |
| CAV State | Shall validate against the CAV State schema. | |
| Road State | Shall validate against the Road State schema. | |
| AMS Data | Shall validate against the AMS Data schema. |
