
Functions
Ref. Model
I/O Data
SubAIMs
JSON MData
Profiles
Ref. Software
Conformance
Performance
1 Functions
The LiDAR Sensors (CAV-LIS) AIM:
| Receives | LiDAR Field | What the LiDAR sensors capture. |
| Produces | Basic LiDAR Object | To Basic LiDAR Scene Description. |
The LiDAR Sensors AIM is the set of LiDAR sensors of the CAV. Each sensor is served by an instance of the LiDAR Object Acquisition AIM, which receives what the sensor captures of the LiDAR Field and provides it as a Basic LiDAR Object: time-stamped on the CAV’s time base, its Qualifier stating the sensor, its intrinsic calibration and its mounting pose on the CAV.
An Implementation instantiates the Acquisition AIM once per sensor; the Basic LiDAR Objects of all sensors leave on one Port, each identifying its sensor.
2 Reference Model
Figure 1 depicts the Reference Model of the LiDAR Sensors (CAV-LIS) AIM.
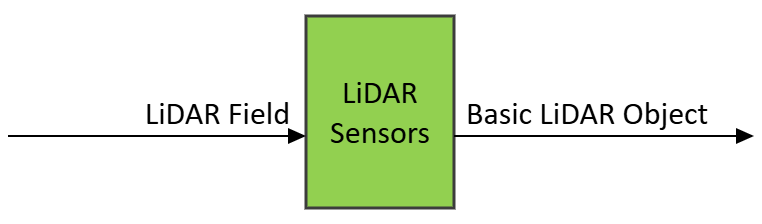
Figure 1 – The LiDAR Sensors (CAV-LIS) AIM
3 I/O Data
Table 1 specifies the Input and Output Data of the LiDAR Sensors (CAV-LIS) AIM.
| Input | Data Type | Description |
|---|---|---|
| LiDAR Field | Basic LiDAR Object | The LiDAR Field as each sensor captures it. |
| Output | Data Type | Description |
| Basic LiDAR Object | Basic LiDAR Object | One Basic LiDAR Object per capture, time-stamped on the CAV’s time base, its Qualifier stating the sensor, its intrinsic calibration and its mounting pose on the CAV. |
4 SubAIMs
One instance of the LiDAR Object Acquisition AIM per sensor.
5 JSON Metadata
https://schemas.mpai.community/CAV2/V2.0/AIMs/LiDARSensors.json
6 Profiles
No Profiles.
7 Reference Software
Not implemented in the reference software of Stage 1.
8 Conformance Testing
Table 2 provides the Conformance Testing Method for the LiDAR Sensors (CAV-LIS) AIM: the data it receives and produces. If a schema references other schemas, conformance of data for the primary schema implies that data referencing a secondary schema shall also validate against that schema, if present, and conform with the Qualifier, if present.
| Receives | Basic LiDAR Object | Shall validate against the Basic LiDAR Object schema. |
| Produces | Basic LiDAR Object | Shall validate against the Basic LiDAR Object schema. |
