
Functions
Ref. Model
I/O Data
SubAIMs
JSON MData
Profiles
Ref. Software
Conformance
Performance
1 Functions
The Route Selection Planning (CAV-RSP) AIM:
| Receives | Basic Offline Map Object | The roads the CAV moves on, and the names of places. |
| Full Environment Descriptors | From Full Environment Description. | |
| AMS Data | From AMS Memory. | |
| AMS-HCI Message Request | From Human-CAV Interaction. | |
| Route | A Route given to be driven. | |
| Route Request | From Trajectory Planning and Decision. | |
| Produces | AMS-HCI Message Response | To Human-CAV Interaction. |
| Route Response | To Trajectory Planning and Decision. | |
| AMS Data | To AMS Memory. | |
| Route | To AMS Memory. |
From the segment the CAV is on and a Destination, the AIM gives the Route of least expected time on the Offline Map – each segment’s time from its length and speed limit – and, where the map has one, the best Route that leaves out a segment of it. It proposes them to Human-CAV Interaction, each segment with the time the CAV is expected at its end, and none where the Destination cannot be reached.
The CAV does not move until Human-CAV Interaction selects a Route with the Route Command Execute. Suspend and Stop halt the CAV at the end of the segment it is on; Resume drives on. A new Destination is proposed again, the Route being driven kept until another is executed. Each Route Command is answered with the Route’s state, and Arrived is told when the CAV stands at the end of its Route.
A new Route is given on a Route Request – a segment that cannot be driven – or when the CAV is found on a segment the Route does not have.
2 Reference Model
Figure 1 depicts the Reference Model of the Route Selection Planning (CAV-RSP) AIM.
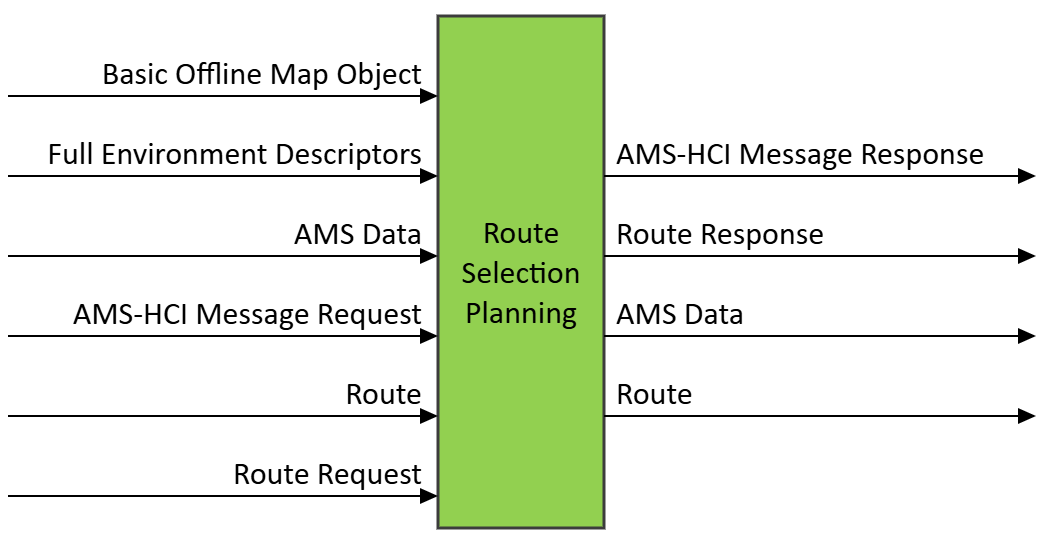
Figure 1 – The Route Selection Planning (CAV-RSP) AIM
3 I/O Data
Table 1 specifies the Input and Output Data of the Route Selection Planning (CAV-RSP) AIM.
| Input | Data Type | Description |
|---|---|---|
| Basic Offline Map Object | Basic Offline Map Object | The Offline Map: its segments, lanes, speed limits and named way points. |
| Full Environment Descriptors | Full Environment Descriptors | Where the CAV is on the map: the segment it is on. |
| AMS Data (optional) | AMS Data | What the AMS has decided before. |
| AMS-HCI Message Request | AMS-HCI Message Request | The Destination requested, the Route selected and the Route Command: Execute, Suspend, Resume, Change, Stop. |
| Route (optional) | Route | A Route given from outside the AMS. |
| Route Request (optional) | Interaction Request | A segment of the Route that cannot be driven. |
| Output | Data Type | Description |
| AMS-HCI Message Response (optional) | AMS-HCI Message Response | The Routes to the Destination, each segment with the time the CAV is expected at its end; the Route’s state (Route Status). |
| Route Response | Interaction Response | The Route to be driven, on which a Path is planned. |
| AMS Data (optional) | AMS Data | The record of the decision. |
| Route | Route | The Route selected. |
4 SubAIMs
No SubAIMs.
5 JSON Metadata
https://schemas.mpai.community/CAV2/V2.0/AIMs/RouteSelectionPlanning.json
6 Profiles
No Profiles.
7 Reference Software
The reference software gives the Route of least time by A* on the Offline Map, each segment’s time from its length and speed limit, and the best alternative that leaves out a segment of it; it holds the CAV until a Route is executed, and answers each Route Command with the Route’s state. It is part of the reference software of CAV-TEC V2.0 (see N4195, An introduction to the reference software): C# on .NET 10, released under the BSD 3-Clause licence, obtained from MPAI.
Tested with the Autonomous Motion Subsystem in dialogue with Human-CAV Interaction: Routes proposed, executed, suspended, resumed, stopped, a Destination changed while driving, the arrival told.
8 Conformance Testing
Table 2 provides the Conformance Testing Method for the Route Selection Planning (CAV-RSP) AIM: the data it receives and produces. If a schema references other schemas, conformance of data for the primary schema implies that data referencing a secondary schema shall also validate against that schema, if present, and conform with the Qualifier, if present.
| Receives | Basic Offline Map Object | Shall validate against the Basic Offline Map Object schema. |
| Full Environment Descriptors | Shall validate against the Full Environment Descriptors schema. | |
| AMS Data | Shall validate against the AMS Data schema. | |
| AMS-HCI Message Request | Shall validate against the AMS-HCI Message schema. | |
| Route | Shall validate against the Route schema. | |
| Interaction Request | Shall validate against the Interaction schema. | |
| Produces | AMS-HCI Message Response | Shall validate against the AMS-HCI Message schema. |
| Interaction Response | Shall validate against the Interaction schema. | |
| AMS Data | Shall validate against the AMS Data schema. | |
| Route | Shall validate against the Route schema. |
