Functions
Ref. Model
I/O Data
SubAIMs
JSON MData
Profiles
Ref. Software
Conformance
Performance
1 Functions
The AMS Memory (CAV-AMM) AIM:
| Receives | Full Environment Descriptors | From Full Environment Description. |
| Route | From Route Selection Planning. | |
| Path | From Path Selection Planning. | |
| Trajectory | From Motion Selection Planning. | |
| Alert | From the Environment Sensing Subsystem. | |
| Road State | From Traffic Obstacle Avoidance. | |
| CAV State | From Traffic Obstacle Avoidance. | |
| AMS-MAS Message Request | From Traffic Obstacle Avoidance. | |
| Produces | AMS Data | Outside the CAV. |
The AIM keeps every decision the Autonomous Motion Subsystem takes – Route, Path, Trajectory, Alert, AMS-MAS Message – in the Private Storage of the Module, with the Full Environment Descriptors it was taken on. For each AMS-MAS Message it gives the AMS Data of that instant: the Route in force, the Path, the Trajectory commanded, the latest Alert since the last, and the Full Environment Descriptors.
The AMS Data is kept in the Shared Storage of the Module: every AIM of the AMS writes it and reads it, and the parties the Shared Storage authorises may read it. The AIM keeps the record: what to keep, and for how long.
2 Reference Model
Figure 1 depicts the Reference Model of the AMS Memory (CAV-AMM) AIM.
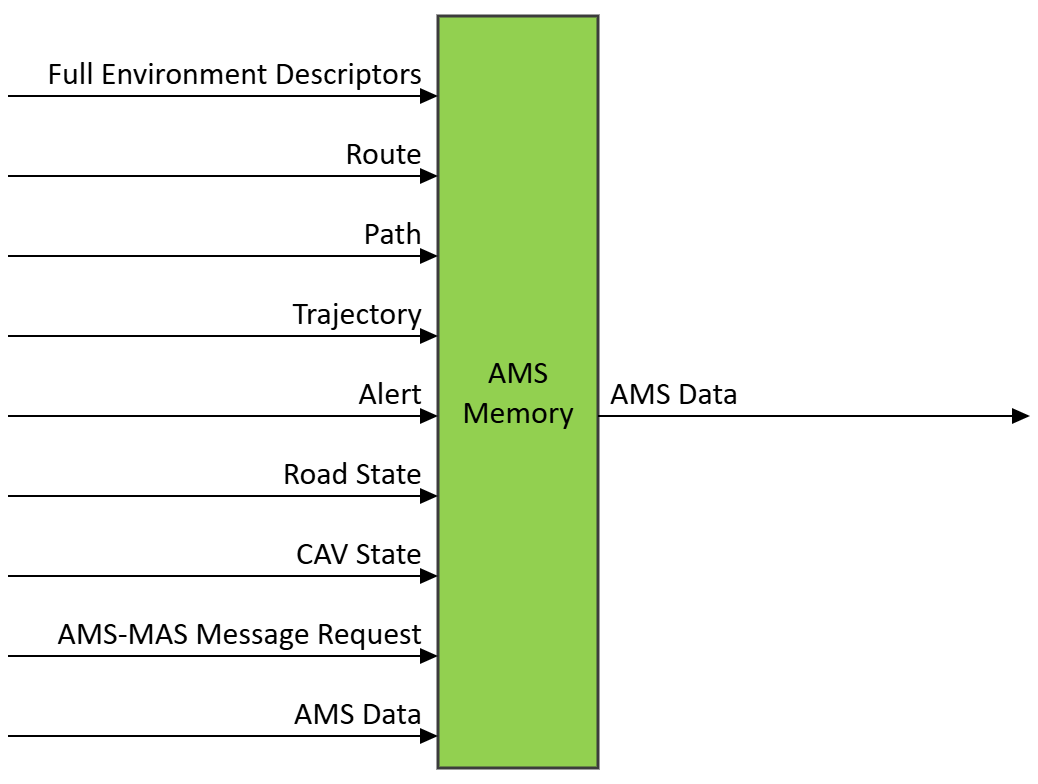
Figure 1 – The AMS Memory (CAV-AMM) AIM
3 I/O Data
Table 1 specifies the Input and Output Data of the AMS Memory (CAV-AMM) AIM.
| Input | Data Type | Description |
|---|---|---|
| Full Environment Descriptors (optional) | Full Environment Descriptors | The descriptors each decision is taken on. |
| Route (optional) | Route | The Route selected. |
| Path (optional) | Path | The Path selected. |
| Trajectory (optional) | Trajectory | The Trajectory planned. |
| Alert (optional) | Alert | An Alert. |
| Road State (optional) | Road State | The state of the road. |
| CAV State (optional) | CAV State | The state of the CAV. |
| AMS-MAS Message Request (optional) | AMS-MAS Message Request | The Trajectory commanded. |
| Output | Data Type | Description |
| AMS Data | AMS Data | For each AMS-MAS Message: the Route in force, the Path, the Trajectory commanded, the latest Alert and the Full Environment Descriptors. |
4 SubAIMs
No SubAIMs.
5 JSON Metadata
https://schemas.mpai.community/CAV2/V2.0/AIMs/AMSMemory.json
6 Profiles
No Profiles.
7 Reference Software
The reference software keeps every decision of the AMS – Route, Path, Trajectory, Alert, AMS-MAS Message – in the Private Storage of the Module with the Full Environment Descriptors it was taken on, and gives the AMS Data of each AMS-MAS Message. It is part of the reference software of CAV-TEC V2.0 (see N4195, An introduction to the reference software): C# on .NET 10, released under the BSD 3-Clause licence, obtained from MPAI.
Tested with the Autonomous Motion Subsystem, Stage 1: the memory and the record of a drive.
8 Conformance Testing
Table 2 provides the Conformance Testing Method for the AMS Memory (CAV-AMM) AIM: the data it receives and produces. If a schema references other schemas, conformance of data for the primary schema implies that data referencing a secondary schema shall also validate against that schema, if present, and conform with the Qualifier, if present.
| Receives | Full Environment Descriptors | Shall validate against the Full Environment Descriptors schema. |
| Route | Shall validate against the Route schema. | |
| Path | Shall validate against the Path schema. | |
| Trajectory | Shall validate against the Trajectory schema. | |
| Alert | Shall validate against the Alert schema. | |
| Road State | Shall validate against the Road State schema. | |
| CAV State | Shall validate against the CAV State schema. | |
| AMS-MAS Message Request | Shall validate against the AMS-MAS Message schema. | |
| Produces | AMS Data | Shall validate against the AMS Data schema. |
