
Functions
Ref. Model
I/O Data
SubAIMs
JSON MData
Profiles
Ref. Software
Conformance
Performance
1 Functions
The Basic Environment Description (CAV-BED) AIM:
| Receives | Basic Audio Scene Descriptors | From Basic Audio Scene Description. |
| Basic Visual Scene Descriptors | From Basic Visual Scene Description. | |
| Basic RADAR Scene Descriptors | From Basic RADAR Scene Description. | |
| Basic LiDAR Scene Descriptors | From Basic LiDAR Scene Description. | |
| Basic Ultrasound Scene Descriptors | From Basic Ultrasound Scene Description. | |
| Basic Offline Map Scene Descriptors | From Basic Offline Map Scene Description. | |
| Spatial Attitude | From Spatial Attitude Generation. | |
| Weather Data | From the boundary of the ESS. | |
| Full Environment Descriptors | From the Autonomous Motion Subsystem. | |
| Produces | Basic Environment Descriptors | To the Autonomous Motion Subsystem. |
The AIM fuses the Basic Scene Descriptors of every Environment Sensing Technology and of the Offline Map into the Basic Environment Descriptors, on the ego frame. Each object perceived is associated with the track nearest to where that track was going, within a gate; the track’s position and velocity are estimated by a filter; its existence confidence is raised by each association and lowered by each miss, and a track missed too often is dropped.
A track in the CAV’s lane close ahead is kept while unseen, moving at its own speed, which falls: a sensor may lose what is near and large before it is gone. Where no descriptors come for a time – a sensor stopped – the tracks are predicted, and the descriptors are given all the same: the Subsystem goes on, and what it no longer senses fades. Nothing is given before the ego Spatial Attitude is known.
2 Reference Model
Figure 1 depicts the Reference Model of the Basic Environment Description (CAV-BED) AIM.
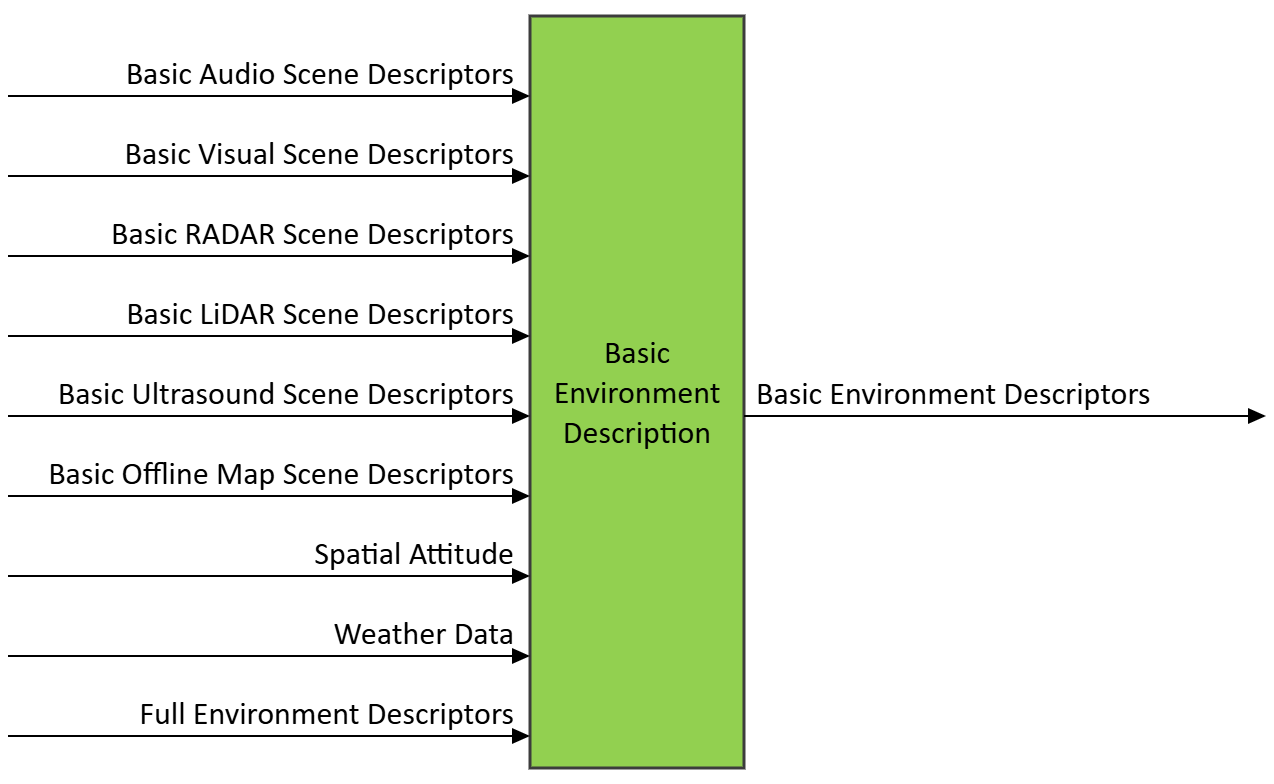
Figure 1 – The Basic Environment Description (CAV-BED) AIM
3 I/O Data
Table 1 specifies the Input and Output Data of the Basic Environment Description (CAV-BED) AIM.
| Input | Data Type | Description |
|---|---|---|
| Basic Audio Scene Descriptors (optional) | Basic Audio Scene Descriptors | What the Audio sensors perceive. |
| Basic Visual Scene Descriptors (optional) | Basic Visual Scene Descriptors | What the Visual sensors perceive. |
| Basic RADAR Scene Descriptors (optional) | Basic RADAR Scene Descriptors | What the RADAR sensors perceive. |
| Basic LiDAR Scene Descriptors (optional) | Basic LiDAR Scene Descriptors | What the LiDAR sensors perceive. |
| Basic Ultrasound Scene Descriptors (optional) | Basic Ultrasound Scene Descriptors | What the Ultrasound sensors perceive. |
| Basic Offline Map Scene Descriptors (optional) | Basic Offline Map Scene Descriptors | What the Offline Map says of the surroundings. |
| Spatial Attitude | Spatial Attitude | The ego Spatial Attitude: the frame of the descriptors. |
| Weather Data (optional) | Weather Data | The weather, as the CAV’s sensors measure it. |
| Full Environment Descriptors (optional) | Full Environment Descriptors | The environment as the AMS has placed it on the map. |
| Output | Data Type | Description |
| Basic Environment Descriptors | Basic Environment Descriptors | The objects around the CAV, fused from every Environment Sensing Technology, on the ego frame. |
4 SubAIMs
No SubAIMs.
5 JSON Metadata
https://schemas.mpai.community/CAV2/V2.0/AIMs/BasicEnvironmentDescription.json
6 Profiles
No Profiles.
7 Reference Software
The reference software fuses one technology, the visual, with what the fusion of several does per technology: each object associated with the nearest track within a gate, the track estimated by an alpha-beta filter, its existence confidence raised and lowered, a track close ahead in the lane kept while unseen; the descriptors given on the ego frame and returned as prior. It is part of the reference software of CAV-TEC V2.0 (see N4195, An introduction to the reference software): C# on .NET 10, released under the BSD 3-Clause licence, obtained from MPAI.
Tested with the Environment Sensing Subsystem, Stage 1, on synthetic drives: objects tracked against the ground truth.
8 Conformance Testing
Table 2 provides the Conformance Testing Method for the Basic Environment Description (CAV-BED) AIM: the data it receives and produces. If a schema references other schemas, conformance of data for the primary schema implies that data referencing a secondary schema shall also validate against that schema, if present, and conform with the Qualifier, if present.
| Receives | Basic Audio Scene Descriptors | Shall validate against the Basic Audio Scene Descriptors schema. |
| Basic Visual Scene Descriptors | Shall validate against the Basic Visual Scene Descriptors schema. | |
| Basic RADAR Scene Descriptors | Shall validate against the Basic RADAR Scene Descriptors schema. | |
| Basic LiDAR Scene Descriptors | Shall validate against the Basic LiDAR Scene Descriptors schema. | |
| Basic Ultrasound Scene Descriptors | Shall validate against the Basic Ultrasound Scene Descriptors schema. | |
| Basic Offline Map Scene Descriptors | Shall validate against the Basic Offline Map Scene Descriptors schema. | |
| Spatial Attitude | Shall validate against the Spatial Attitude schema. | |
| Weather Data | Shall validate against the Weather Data schema. | |
| Full Environment Descriptors | Shall validate against the Full Environment Descriptors schema. | |
| Produces | Basic Environment Descriptors | Shall validate against the Basic Environment Descriptors schema. |
