
Functions
Ref. Model
I/O Data
SubAIMs
JSON MData
Profiles
Ref. Software
Conformance
Performance
1 Functions
The MAS Response Analysis (CAV-MRA) AIM:
| Receives | AMS-MAS Message Request | From the Autonomous Motion Subsystem. |
| Spatial Attitude | From MAS Spatial Attitude Generation. | |
| Brake Response | From the brakes. | |
| Motor Response | From the motor. | |
| Wheel Response | From the steered wheels. | |
| Road State | From Ice Condition Analysis. | |
| Produces | AMS-MAS Message Response | To the Autonomous Motion Subsystem. |
The AIM answers each AMS-MAS Message with the latest Spatial Attitude of the MAS, on its own frame, and the latest Road State, so that the AMS knows what the CAV can do: a CAV on ice brakes less. The Responses of the devices are kept, the latest of each, for a later version to judge what was executed against what was asked.
2 Reference Model
Figure 1 depicts the Reference Model of the MAS Response Analysis (CAV-MRA) AIM.
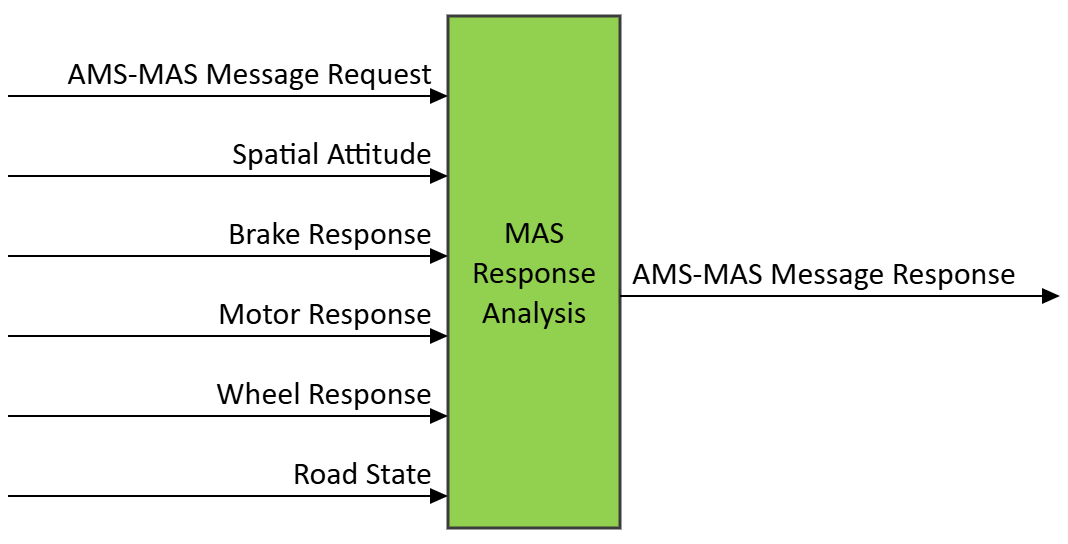
Figure 1 – The MAS Response Analysis (CAV-MRA) AIM
3 I/O Data
Table 1 specifies the Input and Output Data of the MAS Response Analysis (CAV-MRA) AIM.
| Input | Data Type | Description |
|---|---|---|
| AMS-MAS Message Request | AMS-MAS Message Request | The message to answer. |
| Spatial Attitude (optional) | Spatial Attitude | Where the CAV is, on the MAS’s frame. |
| Brake Response (optional) | Brake Response | What was executed of the brakes. |
| Motor Response (optional) | Motor Response | What was executed of the motor. |
| Wheel Response (optional) | Wheel Response | What was executed of the steered wheels. |
| Road State | Road State | The friction the road offers. |
| Output | Data Type | Description |
| AMS-MAS Message Response | AMS-MAS Message Response | The answer: the latest Spatial Attitude of the MAS and the latest Road State. |
4 SubAIMs
No SubAIMs.
5 JSON Metadata
https://schemas.mpai.community/CAV2/V2.0/AIMs/MASResponseAnalysis.json
6 Profiles
No Profiles.
7 Reference Software
The reference software answers each AMS-MAS Message with the latest Spatial Attitude of the MAS and the latest Road State, and keeps the latest Response of each device. It is part of the reference software of CAV-TEC V2.0 (see N4195, An introduction to the reference software): C# on .NET 10, released under the BSD 3-Clause licence, obtained from MPAI.
Tested with the Motion Actuation Subsystem end to end.
8 Conformance Testing
Table 2 provides the Conformance Testing Method for the MAS Response Analysis (CAV-MRA) AIM: the data it receives and produces. If a schema references other schemas, conformance of data for the primary schema implies that data referencing a secondary schema shall also validate against that schema, if present, and conform with the Qualifier, if present.
| Receives | AMS-MAS Message Request | Shall validate against the AMS-MAS Message schema. |
| Spatial Attitude | Shall validate against the Spatial Attitude schema. | |
| Brake Response | Shall validate against the Brake Response schema. | |
| Motor Response | Shall validate against the Motor Response schema. | |
| Wheel Response | Shall validate against the Wheel Response schema. | |
| Road State | Shall validate against the Road State schema. | |
| Produces | AMS-MAS Message Response | Shall validate against the AMS-MAS Message schema. |
