Functions
Ref. Model
I/O Data
SubAIMs
JSON MData
Profiles
Ref. Software
Conformance
Performance
1 Functions
The Autonomous Motion Subsystem (CAV-AMS) AIM:
| Receives | Basic Environment Descriptors | From the Environment Sensing Subsystem. |
| Basic Offline Map Object | The Offline Map. | |
| AMS-HCI Message Request | From Human-CAV Interaction. | |
| Alert | From the Environment Sensing Subsystem. | |
| AMS-MAS Message Response | From the Motion Actuation Subsystem. | |
| Ego-Remote AMS Message | From Remote CAVs in range. | |
| Produces | AMS-HCI Message Response | To Human-CAV Interaction. |
| AMS-MAS Message Request | To the Motion Actuation Subsystem. | |
| AMS Data | Outside the CAV. | |
| Basic MM Scene Descriptors | To Human-CAV Interaction, to render. | |
| Ego-Remote AMS Message | To Remote CAVs in range. |
The AIM plans and decides how the CAV moves. It places on the Offline Map what the Environment Sensing Subsystem perceives and what Remote CAVs report; it proposes to Human-CAV Interaction the Routes to the Destination the passenger asks for and drives the one selected; it plans the Path and the Trajectory and gives the Motion Actuation Subsystem the AMS-MAS Messages that execute them; it records every decision.
The AMS Data, what the AMS decides and what is worth recording for the future, is kept in the Shared Storage of the Module. Every AIM of the AMS writes it and reads it, and the parties the Shared Storage authorises may read it. What an AIM needs only for its own work it keeps in its Private Storage.
2 Reference Model
Figure 1 depicts the Reference Model of the Autonomous Motion Subsystem (CAV-AMS) AIM.
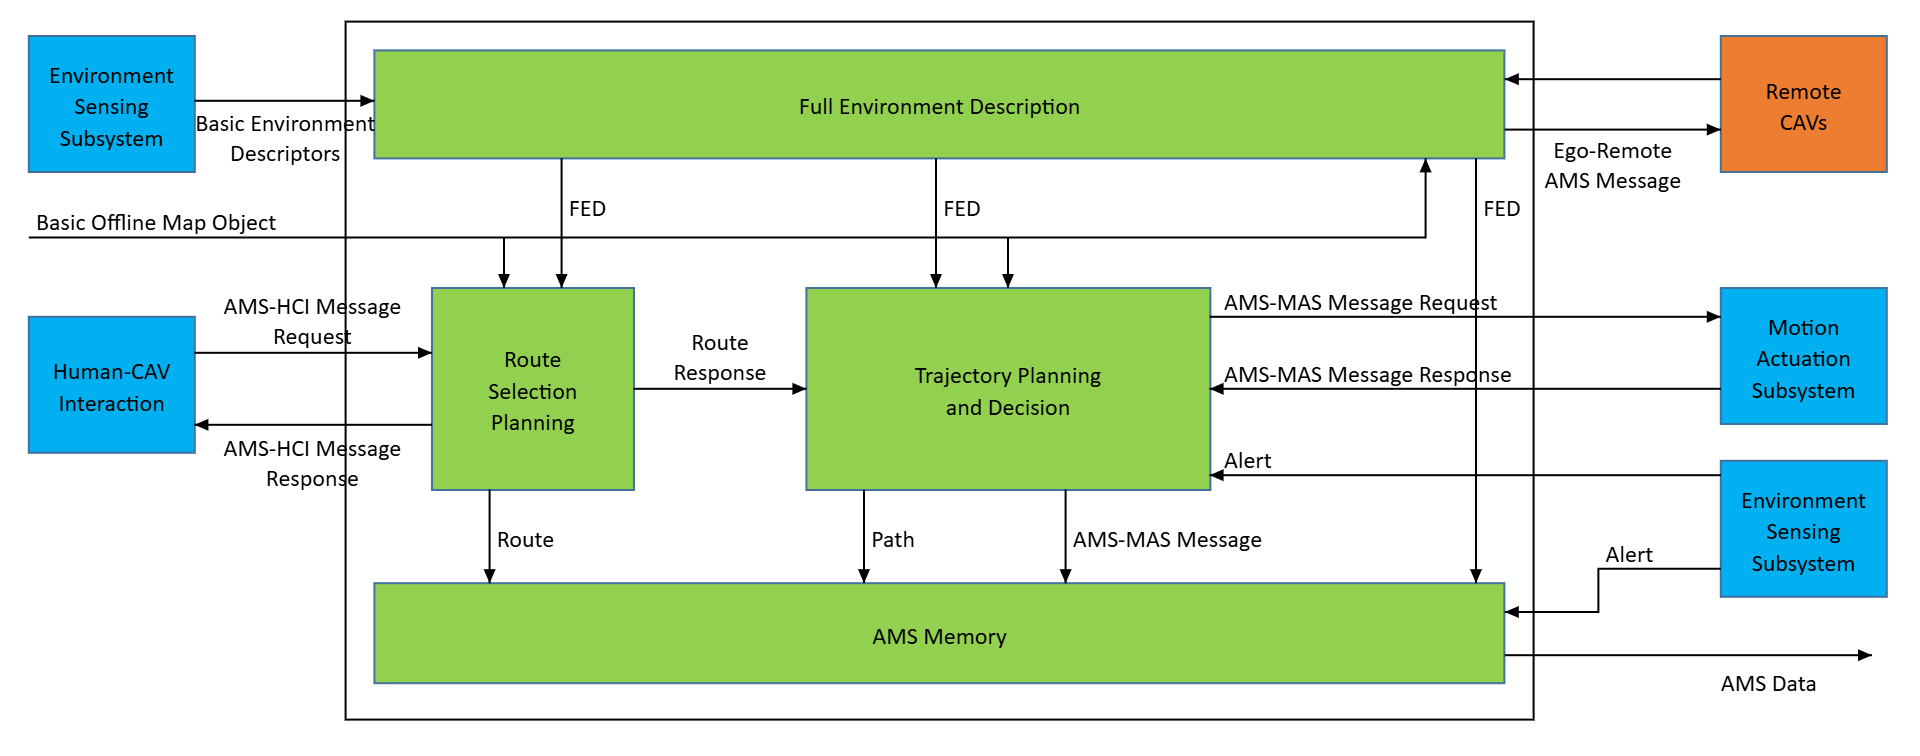
Figure 1 – The Autonomous Motion Subsystem (CAV-AMS) AIM
3 I/O Data
Table 1 specifies the Input and Output Data of the Autonomous Motion Subsystem (CAV-AMS) AIM.
| Input | Data Type | Description |
|---|---|---|
| Basic Environment Descriptors | Basic Environment Descriptors | The objects around the CAV, on the ego frame. |
| Basic Offline Map Object | Basic Offline Map Object | The roads, lanes, speed limits and named places. |
| AMS-HCI Message Request | AMS-HCI Message Request | The Destination, the Route selected and the Route Command. |
| Alert (optional) | Alert | Something that calls for an immediate reaction. |
| AMS-MAS Message Response (optional) | AMS-MAS Message Response | The MAS’s answer: its Spatial Attitude and the Road State. |
| Ego-Remote AMS Message (optional) | Ego-Remote AMS Message | What another CAV perceives. |
| Output | Data Type | Description |
| AMS-HCI Message Response (optional) | AMS-HCI Message Response | The Routes proposed; the Route’s state (Route Status). |
| AMS-MAS Message Request | AMS-MAS Message Request | The Trajectory to execute, with the Command. |
| AMS Data | AMS Data | The record of every decision. |
| Basic MM Scene Descriptors (optional) | Basic MM Scene Descriptors | The scene around the CAV, from the Full Environment Descriptors, for Human-CAV Interaction to render from the passenger’s Point of View. |
| Ego-Remote AMS Message (optional) | Ego-Remote AMS Message | What the CAV perceives. |
4 SubAIMs
4.1 Functions of SubAIMs
Table 2 specifies the Functions of the SubAIMs of the Autonomous Motion Subsystem (CAV-AMS) AIM.
| SubAIM | Function |
|---|---|
| Full Environment Description | The CAV and every object around it – those it perceives and those Remote CAVs report – placed on the Offline Map. |
| Route Selection Planning | The Routes to the Destination proposed to Human-CAV Interaction; the one selected driven; the Route’s state told. |
| Trajectory Planning and Decision | From the Route, the Path, the Trajectory and the AMS-MAS Message. |
| AMS Memory | Every decision recorded with the Full Environment Descriptors it was taken on; the AMS Data. |
4.2 Operation
Full Environment Description places on the Offline Map, at each instant, the objects the Environment Sensing Subsystem perceives and those Remote CAVs report, and sends to Remote CAVs what the CAV perceives.
When Human-CAV Interaction requests a Destination, Route Selection Planning proposes the Routes to it; the CAV does not move until one is selected with Execute. The Route to be driven is given to Trajectory Planning and Decision as a Route Response; each Route Command is answered with the Route’s state.
For each Full Environment Descriptors instance, Trajectory Planning and Decision gives the AMS-MAS Message Request to the Motion Actuation Subsystem, bounded by its AMS-MAS Message Response and by the Alerts. AMS Memory records the Route, the Path, the AMS-MAS Messages and the Alerts with the Full Environment Descriptors, and gives the AMS Data.
4.3 I/O Data of SubAIMs
Table 3 specifies the Input and Output Data of the SubAIMs.
| SubAIM | Input | Output |
|---|---|---|
| Full Environment Description | Basic Offline Map Object – Basic Offline Map Object Basic Environment Descriptors – Basic Environment Descriptors Full Environment Descriptors – Full Environment Descriptors Road State – Road State CAV State – CAV State Ego-Remote AMS Message – Ego-Remote AMS Message |
Ego-Remote AMS Message – Ego-Remote AMS Message Full Environment Descriptors – Full Environment Descriptors Basic MM Scene Descriptors – Basic MM Scene Descriptors |
| Route Selection Planning | Basic Offline Map Object – Basic Offline Map Object Full Environment Descriptors – Full Environment Descriptors AMS-HCI Message Request – AMS-HCI Message Route – Route Route Request – Interaction |
AMS-HCI Message Response – AMS-HCI Message Route Response – Interaction Route – Route |
| Trajectory Planning and Decision | Basic Offline Map Object – Basic Offline Map Object Alert – Alert AMS-MAS Message Response – AMS-MAS Message Full Environment Descriptors – Full Environment Descriptors Route Response – Interaction |
Route Request – Interaction Full Environment Descriptors – Full Environment Descriptors AMS-MAS Message Request – AMS-MAS Message Path – Path CAV State – CAV State Road State – Road State |
| AMS Memory | Full Environment Descriptors – Full Environment Descriptors Route – Route Path – Path Trajectory – Trajectory Alert – Alert Road State – Road State CAV State – CAV State AMS-MAS Message Request – AMS-MAS Message |
4.4 AIMs and JSON Metadata
Table 4 gives the AIMs and their JSON Metadata.
5 JSON Metadata
https://schemas.mpai.community/CAV2/V2.0/AIMs/AutonomousMotionSubsystem.json
6 Profiles
No Profiles.
7 Reference Software
The reference software implements every Sub-AIM of the AMS, run continuously, recording Always. It is part of the reference software of CAV-TEC V2.0 (see N4195, An introduction to the reference software): C# on .NET 10, released under the BSD 3-Clause licence, obtained from MPAI.
Tested end to end on perfect perception and with the Environment Sensing Subsystem; in dialogue with Human-CAV Interaction; with two CAVs exchanging what they perceive.
8 Conformance Testing
Table 5 provides the Conformance Testing Method for the Autonomous Motion Subsystem (CAV-AMS) AIM: the data it receives and produces. If a schema references other schemas, conformance of data for the primary schema implies that data referencing a secondary schema shall also validate against that schema, if present, and conform with the Qualifier, if present.
| Receives | Basic Environment Descriptors | Shall validate against the Basic Environment Descriptors schema. |
| Basic Offline Map Object | Shall validate against the Basic Offline Map Object schema. | |
| AMS-HCI Message Request | Shall validate against the AMS-HCI Message schema. | |
| Alert | Shall validate against the Alert schema. | |
| AMS-MAS Message Response | Shall validate against the AMS-MAS Message schema. | |
| Ego-Remote AMS Message | Shall validate against the Ego-Remote AMS Message schema. | |
| Produces | AMS-HCI Message Response | Shall validate against the AMS-HCI Message schema. |
| AMS-MAS Message Request | Shall validate against the AMS-MAS Message schema. | |
| AMS Data | Shall validate against the AMS Data schema. | |
| Basic MM Scene Descriptors | Shall validate against the Basic Multimodal Scene Descriptors schema. | |
| Ego-Remote AMS Message | Shall validate against the Ego-Remote AMS Message schema. |
