
Functions
Ref. Model
I/O Data
SubAIMs
JSON MData
Profiles
Ref. Software
Conformance
Performance
1 Functions
The Motion Actuation Subsystem (CAV-MAS) AIM:
| Receives | Spatial Data | From the CAV’s motion sensors. |
| Weather Data | From the CAV’s weather sensors. | |
| AMS-MAS Message Request | From the Autonomous Motion Subsystem. | |
| Brake Response | From the brakes. | |
| Motor Response | From the motor. | |
| Wheel Response | From the steered wheels. | |
| Produces | Spatial Attitude | To the Environment Sensing Subsystem. |
| Weather Data | To the Environment Sensing Subsystem. | |
| Brake Command | To the brakes. | |
| Motor Command | To the motor. | |
| Wheel Command | To the steered wheels. | |
| AMS-MAS Message Response | To the Autonomous Motion Subsystem. |
The AIM executes the AMS-MAS Messages of the Autonomous Motion Subsystem by the commands of the CAV’s mechanical subsystems – brakes, motor, steered wheels – and answers each message with where the CAV is and the state of the road. It reckons the CAV’s Spatial Attitude from its motion sensors alone and estimates the friction the road offers from what the tyres give. The commands are delivered to the devices by the User Agent.
2 Reference Model
Figure 1 depicts the Reference Model of the Motion Actuation Subsystem (CAV-MAS) AIM.
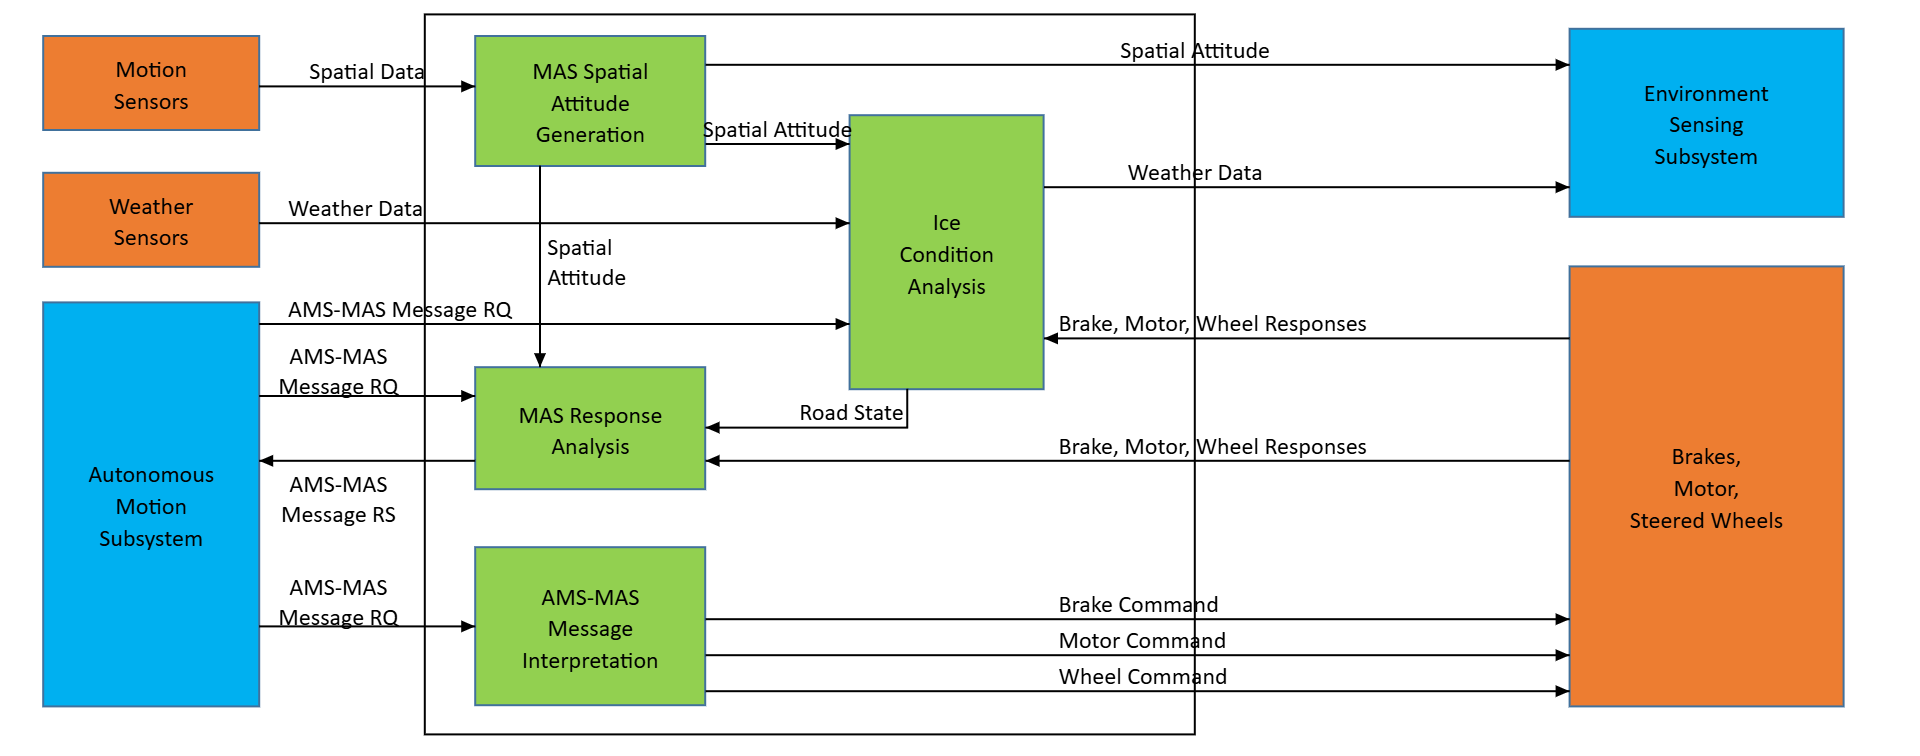
Figure 1 – The Motion Actuation Subsystem (CAV-MAS) AIM
3 I/O Data
Table 1 specifies the Input and Output Data of the Motion Actuation Subsystem (CAV-MAS) AIM.
| Input | Data Type | Description |
|---|---|---|
| Spatial Data | Spatial Data | Odometer, speedometer, accelerometer, inclinometers and gyroscope. |
| Weather Data (optional) | Weather Data | Temperature, precipitation, ice reported. |
| AMS-MAS Message Request | AMS-MAS Message Request | The Trajectory to execute, with the CAV’s Spatial Attitude and the Command. |
| Brake Response (optional) | Brake Response | What was executed of the brakes. |
| Motor Response (optional) | Motor Response | What was executed of the motor. |
| Wheel Response (optional) | Wheel Response | What was executed of the steered wheels. |
| Output | Data Type | Description |
| Spatial Attitude | Spatial Attitude | The CAV’s Spatial Attitude by dead reckoning, on the MAS’s frame. |
| Weather Data (optional) | Weather Data | The weather the MAS has taken into account. |
| Brake Command (optional) | Brake Command | The braking to apply. |
| Motor Command (optional) | Motor Command | The acceleration to give. |
| Wheel Command | Wheel Command | The angle to steer. |
| AMS-MAS Message Response | AMS-MAS Message Response | The answer: the MAS’s Spatial Attitude and the Road State. |
4 SubAIMs
4.1 Functions of SubAIMs
Table 2 specifies the Functions of the SubAIMs of the Motion Actuation Subsystem (CAV-MAS) AIM.
| SubAIM | Function |
|---|---|
| MAS Spatial Attitude Generation | The CAV’s Spatial Attitude by dead reckoning from the motion sensors, on the MAS’s frame. |
| Ice Condition Analysis | The friction the road under the CAV offers, from the tyres and the weather. |
| MAS Response Analysis | The answer to each AMS-MAS Message: the Spatial Attitude and the Road State. |
| AMS-MAS Message Interpretation | The Trajectory followed by the commands of the brakes, the motor and the steered wheels. |
4.2 Operation
At each Spatial Data, MAS Spatial Attitude Generation gives the CAV’s Spatial Attitude, which goes to Ice Condition Analysis, MAS Response Analysis and the Environment Sensing Subsystem, where GNSS anchors it.
AMS-MAS Message Interpretation follows the Trajectory of each AMS-MAS Message Request by the Brake, Motor and Wheel Commands, from the CAV’s Spatial Attitude the Message carries – that of the Autonomous Motion Subsystem; the devices answer with their Responses. Ice Condition Analysis estimates from them, and from the Weather Data, the friction the road offers.
MAS Response Analysis answers each AMS-MAS Message Request with an AMS-MAS Message Response carrying the latest Spatial Attitude of the MAS and the Road State, so that the Autonomous Motion Subsystem plans within what the road allows.
4.3 I/O Data of SubAIMs
Table 3 specifies the Input and Output Data of the SubAIMs.
| SubAIM | Input | Output |
|---|---|---|
| MAS Spatial Attitude Generation | Spatial Data – Spatial Data Wheel Response – Wheel Response |
Spatial Attitude – Spatial Attitude |
| Ice Condition Analysis | Weather Data – Weather Data Spatial Attitude – Spatial Attitude AMS-MAS Message Request – AMS-MAS Message Brake Response – Brake Response Motor Response – Motor Response Wheel Response – Wheel Response |
Road State – Road State Weather Data – Weather Data |
| MAS Response Analysis | AMS-MAS Message Request – AMS-MAS Message Spatial Attitude – Spatial Attitude Brake Response – Brake Response Motor Response – Motor Response Wheel Response – Wheel Response Road State – Road State |
AMS-MAS Message Response – AMS-MAS Message |
| AMS-MAS Message Interpretation | AMS-MAS Message Request – AMS-MAS Message Spatial Attitude – Spatial Attitude Brake Response – Brake Response Motor Response – Motor Response Wheel Response – Wheel Response |
Brake Command – Brake Command Motor Command – Motor Command Wheel Command – Wheel Command AMS-MAS Message Response – AMS-MAS Message |
4.4 AIMs and JSON Metadata
Table 4 gives the AIMs and their JSON Metadata.
5 JSON Metadata
https://schemas.mpai.community/CAV2/V2.0/AIMs/MotionActuationSubsystem.json
6 Profiles
No Profiles.
7 Reference Software
The reference software implements every Sub-AIM of the MAS; its commands are delivered to simulated mechanical subsystems – motor, brakes, steered wheels, tyres, slippery stretches – by the User Agent. It is part of the reference software of CAV-TEC V2.0 (see N4195, An introduction to the reference software): C# on .NET 10, released under the BSD 3-Clause licence, obtained from MPAI.
Tested end to end, the AMS-MAS Messages executed and answered.
8 Conformance Testing
Table 5 provides the Conformance Testing Method for the Motion Actuation Subsystem (CAV-MAS) AIM: the data it receives and produces. If a schema references other schemas, conformance of data for the primary schema implies that data referencing a secondary schema shall also validate against that schema, if present, and conform with the Qualifier, if present.
| Receives | Spatial Data | Shall validate against the Spatial Data schema. |
| Weather Data | Shall validate against the Weather Data schema. | |
| AMS-MAS Message Request | Shall validate against the AMS-MAS Message schema. | |
| Brake Response | Shall validate against the Brake Response schema. | |
| Motor Response | Shall validate against the Motor Response schema. | |
| Wheel Response | Shall validate against the Wheel Response schema. | |
| Produces | Spatial Attitude | Shall validate against the Spatial Attitude schema. |
| Weather Data | Shall validate against the Weather Data schema. | |
| Brake Command | Shall validate against the Brake Command schema. | |
| Motor Command | Shall validate against the Motor Command schema. | |
| Wheel Command | Shall validate against the Wheel Command schema. | |
| AMS-MAS Message Response | Shall validate against the AMS-MAS Message schema. |
